Good Drone, need code for fly
H - Hover Mode
WASD - Move
Shift - down
Space - up
Q,E - Rotate
Code:
-- Инициализация датчиков, пульта и мониторов
local alt_front = peripheral.wrap("altitude_sensor_0")
local alt_back = peripheral.wrap("altitude_sensor_1")
local alt_left = peripheral.wrap("altitude_sensor_2")
local alt_right = peripheral.wrap("altitude_sensor_3")
local typewriter = peripheral.wrap("linked_typewriter_0")
local monitor = peripheral.wrap("monitor_0")
local monitor_ah = peripheral.wrap("monitor_1")
if not (alt_front and alt_back and alt_left and alt_right and typewriter) then
print("ERROR: Not all sensors or linked_typewriter_0 found!")
return
end
if monitor then monitor.setTextScale(1.0) end
-- ================= НАСТРОЙКИ ПОЛЕТА =================
local CLUTCH_SIDE = "right"
local TILT_AMOUNT = 2.5
local YAW_SPEED = 150
local LIFT_POWER = 25
-- Коэффициенты ПИД (Крен, Тангаж, Высота)
local Kp_roll = 1.2; local Ki_roll = 0.03; local Kd_roll = 8.0
local Kp_pitch = 1.5; local Ki_pitch = 0.05; local Kd_pitch = 15.0
local Kp_alt = 2.0; local Ki_alt = 0.05; local Kd_alt = 10.0
local TRIM_PITCH = 10.0; local TRIM_ROLL = 0.0
local HOVER_SPEED = 45; local MIN_THROTTLE = 15; local MAX_SPEED = 256
-- Базовые переменные
local current_throttle = 0; local throttle_step = 0.5
local prev_err_x, prev_err_z, prev_err_y = 0, 0, 0
local int_x, int_z, int_y = 0, 0, 0
-- Переменные Автопилота
local hover_mode = false
local autoland_mode = false
local target_altitude = 0
local prev_avg_alt = 0
local autoland_throttle = 0 -- НОВАЯ ПЕРЕМЕННАЯ ДЛЯ ПЛАВНОЙ ПОСАДКИ
local prev_keys = {}
-- ================= ФУНКЦИЯ ПАМЯТИ =================
local SAVE_FILE = "flight_data.txt"
local save_timer = os.clock()
local function saveState()
local f = fs.open(SAVE_FILE, "w")
if f then
f.writeLine(tostring(current_throttle))
f.writeLine(tostring(int_x))
f.writeLine(tostring(int_z))
f.close()
end
end
local function loadState()
if fs.exists(SAVE_FILE) then
local f = fs.open(SAVE_FILE, "r")
if f then
local t = tonumber(f.readLine())
local ix = tonumber(f.readLine())
local iz = tonumber(f.readLine())
if t and ix and iz then
current_throttle = t; int_x = ix; int_z = iz
end
f.close()
end
end
end
local function resetState()
current_throttle = 0; int_x = 0; int_z = 0; int_y = 0
hover_mode = false; autoland_mode = false; autoland_throttle = 0
saveState()
end
loadState()
-- ================= ВСПОМОГАТЕЛЬНЫЕ ФУНКЦИИ =================
local function clamp(v, min, max)
return v < min and min or (v > max and max or v)
end
local function isPressed(keys_table, code)
if not keys_table then return false end
for _, k in ipairs(keys_table) do
if k == code then return true end
end
return false
end
local function justPressed(keys_now, keys_prev, code)
return isPressed(keys_now, code) and not isPressed(keys_prev, code)
end
local function osd_print(text)
if monitor then
local x, y = monitor.getCursorPos()
monitor.write(text)
monitor.setCursorPos(1, y + 1)
else print(text) end
end
local function draw_artificial_horizon(mon, pitch_err, roll_err, alt)
if not mon then return end
mon.setTextScale(0.5)
local w, h = mon.getSize()
local cx = math.floor(w / 2); local cy = math.floor(h / 2)
local pitch_offset = math.floor(-pitch_err * 2.0)
local roll_slope = roll_err * 0.4
for y = 1, h do
local text_row, fg_row, bg_row = "", "", ""
for x = 1, w do
local horizon_y = cy + pitch_offset + (x - cx) * roll_slope
if y < horizon_y - 0.5 then bg_row = bg_row .. "3"
elseif math.abs(y - horizon_y) <= 0.5 then bg_row = bg_row .. "0"
else bg_row = bg_row .. "c" end
text_row = text_row .. " "; fg_row = fg_row .. "f"
end
mon.setCursorPos(1, y); mon.blit(text_row, fg_row, bg_row)
end
mon.setCursorPos(cx - 3, cy); mon.blit(" >-|-< ", "4444444", "7777777")
mon.setCursorPos(2, 2); mon.setBackgroundColor(colors.black); mon.setTextColor(colors.white)
mon.write(string.format(" ALT: %.1f ", alt))
mon.setCursorPos(2, h - 1)
mon.write(string.format(" P: %0.1f | R: %0.1f ", -pitch_err, -roll_err))
end
-- ================= ГЛАВНЫЙ ЦИКЛ =================
while true do
-- 1. Читаем высотомеры
local ok_f, h_front = pcall(alt_front.getHeight)
local ok_b, h_back = pcall(alt_back.getHeight)
local ok_l, h_left = pcall(alt_left.getHeight)
local ok_r, h_right = pcall(alt_right.getHeight)
local err_x, err_z, avg_alt = 0, 0, 0
if ok_f and ok_b and ok_l and ok_r then
avg_alt = (h_front + h_back + h_left + h_right) / 4.0
end
local vertical_speed = (avg_alt - prev_avg_alt) / 0.05
prev_avg_alt = avg_alt
-- 2. Считываем пульт
local keys = typewriter.getPressedKeyCodes() or {}
local target_x, target_z, manual_throttle, yaw_cmd = 0, 0, 0, 0
local is_turning = false
local input_str = ""
-- Переключатели режимов
if justPressed(keys, prev_keys, 72) then
hover_mode = not hover_mode
if hover_mode then
autoland_mode = false; target_altitude = avg_alt; int_y = 0
end
end
if justPressed(keys, prev_keys, 76) then
autoland_mode = not autoland_mode
if autoland_mode then
hover_mode = false
autoland_throttle = 0 -- Сбрасываем счетчик давления газа при включении посадки
end
end
-- ================= ЛОГИКА АВТОПОСАДКИ =================
if autoland_mode then
input_str = "[ AUTO-LAND ACTIVE ] "
-- Каждые 0.05 сек дрон давит газ всё ниже и ниже (по -0.2 RPM за тик)
autoland_throttle = autoland_throttle - 0.2
manual_throttle = autoland_throttle
-- КАК ПОНЯТЬ, ЧТО МЫ СЕЛИ:
-- 1. Высота почти ноль (если датчики на пузе)
-- 2. ИЛИ мы скинули газ уже очень сильно (-20 RPM), а дрон не двигается вниз (уперлись в землю)
if avg_alt < 0.5 or (autoland_throttle < -20 and math.abs(vertical_speed) < 0.2) then
resetState()
peripheral.call("Create_RotationSpeedController_6", "setTargetSpeed", 0)
end
else
-- Обычное управление
if isPressed(keys, 87) then target_z = -TILT_AMOUNT; input_str = input_str .. "[W] " end
if isPressed(keys, 83) then target_z = TILT_AMOUNT; input_str = input_str .. "[S] " end
if isPressed(keys, 65) then target_x = -TILT_AMOUNT; input_str = input_str .. "[A] " end
if isPressed(keys, 68) then target_x = TILT_AMOUNT; input_str = input_str .. "[D] " end
if isPressed(keys, 81) then yaw_cmd = YAW_SPEED; is_turning = true; input_str = input_str .. "[Q] " end
if isPressed(keys, 69) then yaw_cmd = -YAW_SPEED; is_turning = true; input_str = input_str .. "[E] " end
if hover_mode then
input_str = "[HOVER] " .. input_str
if isPressed(keys, 32) then target_altitude = target_altitude + 0.3; input_str = input_str .. "[UP] " end
if isPressed(keys, 340) then target_altitude = target_altitude - 0.3; input_str = input_str .. "[DN] " end
else
if isPressed(keys, 32) then manual_throttle = LIFT_POWER; input_str = input_str .. "[SPC] " end
if isPressed(keys, 340) then manual_throttle = -LIFT_POWER; input_str = input_str .. "[SHF] " end
end
end
if input_str == "" then input_str = "IDLE" end
prev_keys = keys
-- УПРАВЛЕНИЕ СЦЕПЛЕНИЕМ
if is_turning and not autoland_mode then
redstone.setOutput(CLUTCH_SIDE, false)
peripheral.call("Create_RotationSpeedController_6", "setTargetSpeed", yaw_cmd)
else
redstone.setOutput(CLUTCH_SIDE, true)
end
-- 3. ПИД ВЫСОТЫ (Hover Mode)
local pid_throttle = 0
if hover_mode and not autoland_mode then
local err_y = target_altitude - avg_alt
int_y = clamp(int_y + err_y, -500, 500)
pid_throttle = (Kp_alt * err_y) + (Ki_alt * int_y) + (Kd_alt * (err_y - prev_err_y))
prev_err_y = err_y
else
int_y = 0; prev_err_y = 0
end
-- 4. Расчет газа
local alt_cmd = -peripheral.call("Create_RotationSpeedController_5", "getTargetSpeed")
local target_throttle = HOVER_SPEED + alt_cmd
if hover_mode then target_throttle = target_throttle + pid_throttle
else target_throttle = target_throttle + manual_throttle end
target_throttle = clamp(target_throttle, MIN_THROTTLE, MAX_SPEED)
if current_throttle < target_throttle then
current_throttle = math.min(current_throttle + throttle_step, target_throttle)
elseif current_throttle > target_throttle then
current_throttle = math.max(current_throttle - (throttle_step * 2), target_throttle)
end
local throttle = current_throttle
-- 5. ПИД Наклона
err_z = target_z - (h_front - h_back)
err_x = target_x - (h_left - h_right)
if math.abs(err_x) < 0.1 and target_x == 0 then err_x = 0 end
if math.abs(err_z) < 0.1 and target_z == 0 then err_z = 0 end
if throttle <= MIN_THROTTLE + 5 then
int_x = 0; int_z = 0
else
int_x = clamp(int_x + err_x, -500, 500)
int_z = clamp(int_z + err_z, -500, 500)
end
local output_x = (Kp_roll * err_x) + (Ki_roll * int_x) + (Kd_roll * (err_x - prev_err_x)) - TRIM_ROLL
local output_z = (Kp_pitch * err_z) + (Ki_pitch * int_z) + (Kd_pitch * (err_z - prev_err_z)) - TRIM_PITCH
prev_err_x = err_x; prev_err_z = err_z
-- Микшер
local motor_1 = throttle + output_z + output_x
local motor_2 = throttle + output_z - output_x
local motor_4 = throttle - output_z + output_x
local motor_3 = throttle - output_z - output_x
motor_1 = clamp(motor_1, MIN_THROTTLE, MAX_SPEED); motor_2 = clamp(motor_2, MIN_THROTTLE, MAX_SPEED)
motor_4 = clamp(motor_4, MIN_THROTTLE, MAX_SPEED); motor_3 = clamp(motor_3, MIN_THROTTLE, MAX_SPEED)
peripheral.call("Create_RotationSpeedController_1", "setTargetSpeed", -motor_1)
peripheral.call("Create_RotationSpeedController_2", "setTargetSpeed", -motor_2)
peripheral.call("Create_RotationSpeedController_4", "setTargetSpeed", -motor_4)
peripheral.call("Create_RotationSpeedController_3", "setTargetSpeed", -motor_3)
-- === СИГНАЛИЗАЦИЯ GPWS ===
local alarm_msg = nil
if vertical_speed < -5.0 and avg_alt > 3.0 then
alarm_msg = "!! PULL UP !!"
elseif math.abs(err_x) > 6.0 or math.abs(err_z) > 6.0 then
alarm_msg = "!! BANK ANGLE !!"
end
-- === ОБНОВЛЕНИЕ ГЛАВНОГО ЭКРАНА ===
if monitor then
monitor.clear(); monitor.setCursorPos(1,1)
monitor.write("=== AERONAUTICS FLIGHT OS ===")
monitor.setCursorPos(1,2)
if hover_mode then monitor.write(string.format("PWR: %.1f | ALT: %.1f (Trgt: %.1f)", throttle, avg_alt, target_altitude))
else monitor.write(string.format("PWR: %.1f | ALT: %.1f", throttle, avg_alt)) end
monitor.setCursorPos(1,3); monitor.write("INPUT: " .. input_str)
monitor.setCursorPos(1,4); monitor.write(string.format("PITCH: Trgt %4.1f | Err %5.2f", target_z, err_z))
monitor.setCursorPos(1,5); monitor.write(string.format("ROLL : Trgt %4.1f | Err %5.2f", target_x, err_x))
if alarm_msg then
monitor.setCursorPos(1, 7)
if math.floor(os.clock() * 6) % 2 == 0 then
monitor.setBackgroundColor(colors.red); monitor.setTextColor(colors.white)
else
monitor.setBackgroundColor(colors.black); monitor.setTextColor(colors.red)
end
monitor.write(" " .. alarm_msg .. " ")
monitor.setBackgroundColor(colors.black); monitor.setTextColor(colors.white)
end
monitor.setCursorPos(15, 10)
monitor.setBackgroundColor(colors.red); monitor.setTextColor(colors.white)
monitor.write("[ RESET ]")
monitor.setBackgroundColor(colors.black)
end
if monitor_ah then draw_artificial_horizon(monitor_ah, err_z, err_x, avg_alt) end
-- Сохранение состояния
if os.clock() - save_timer > 1.0 then
saveState(); save_timer = os.clock()
end
-- Ожидание и проверка тачскрина
local timer = os.startTimer(0.05)
while true do
local event, p1, p2, p3 = os.pullEvent()
if event == "monitor_touch" and p1 == "monitor_0" then
if p2 >= 15 and p3 >= 10 then
resetState()
peripheral.call("Create_RotationSpeedController_6", "setTargetSpeed", 0)
end
elseif event == "timer" and p1 == timer then
break
end
end
end

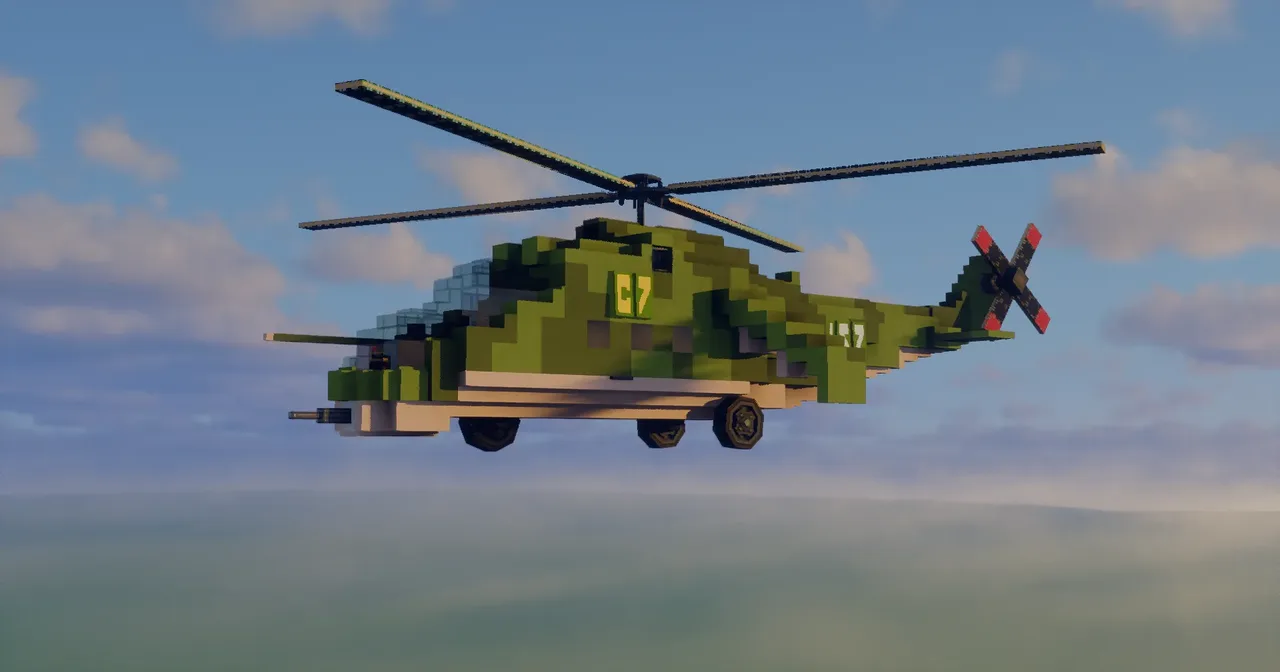 Mil Mi-24798 blocks · Matigamer1400
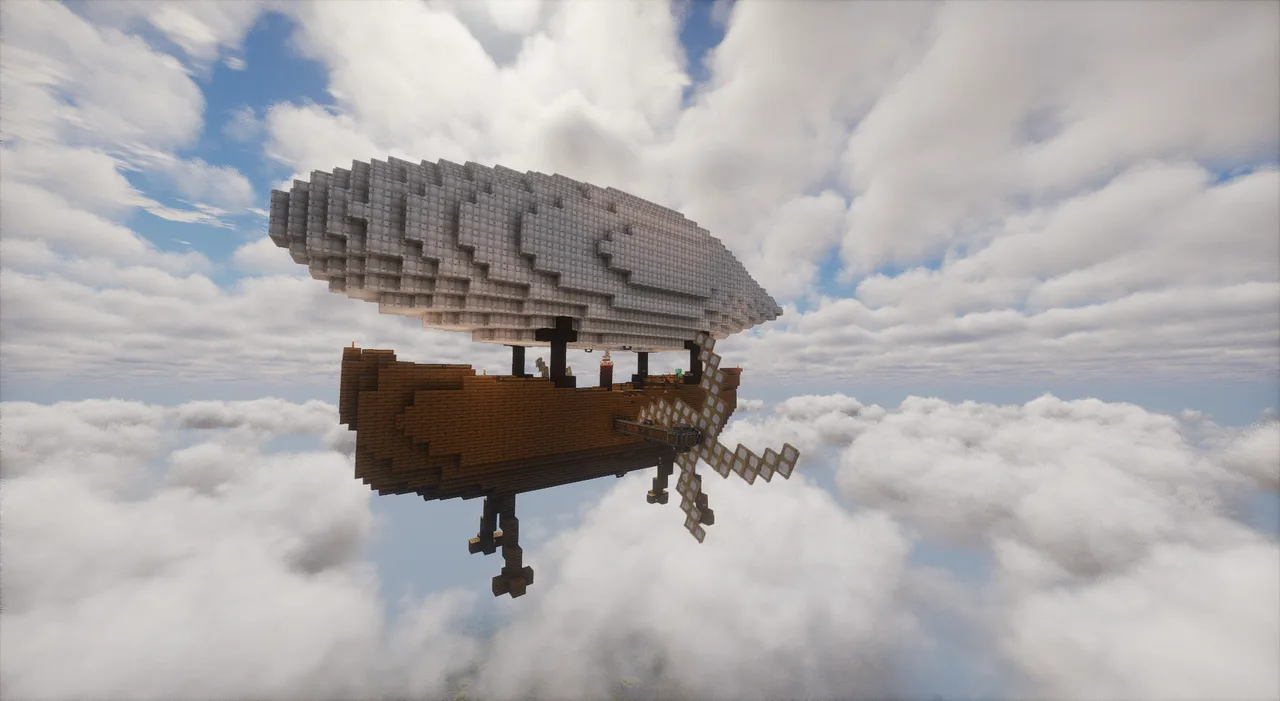 Big Airship Base4,579 blocks · Mark02
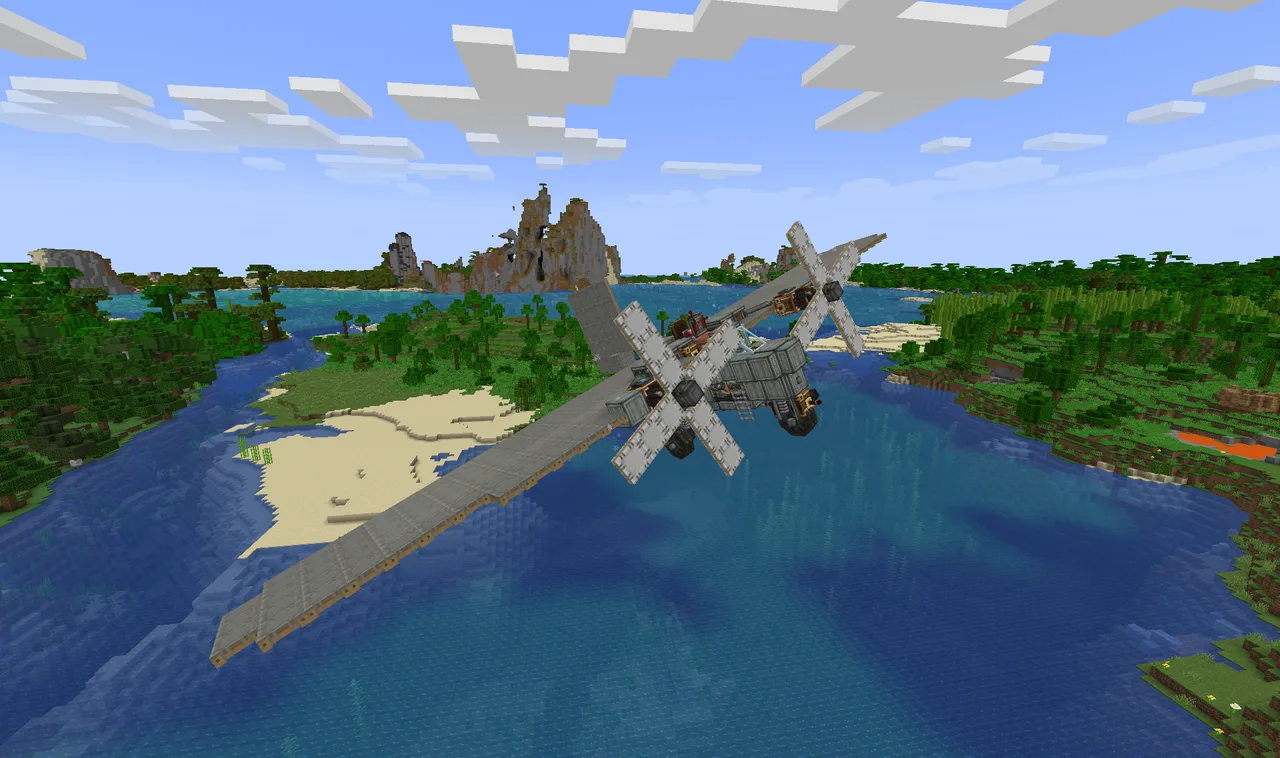 Single Seat Airplane388 blocks · Industrial Dragon
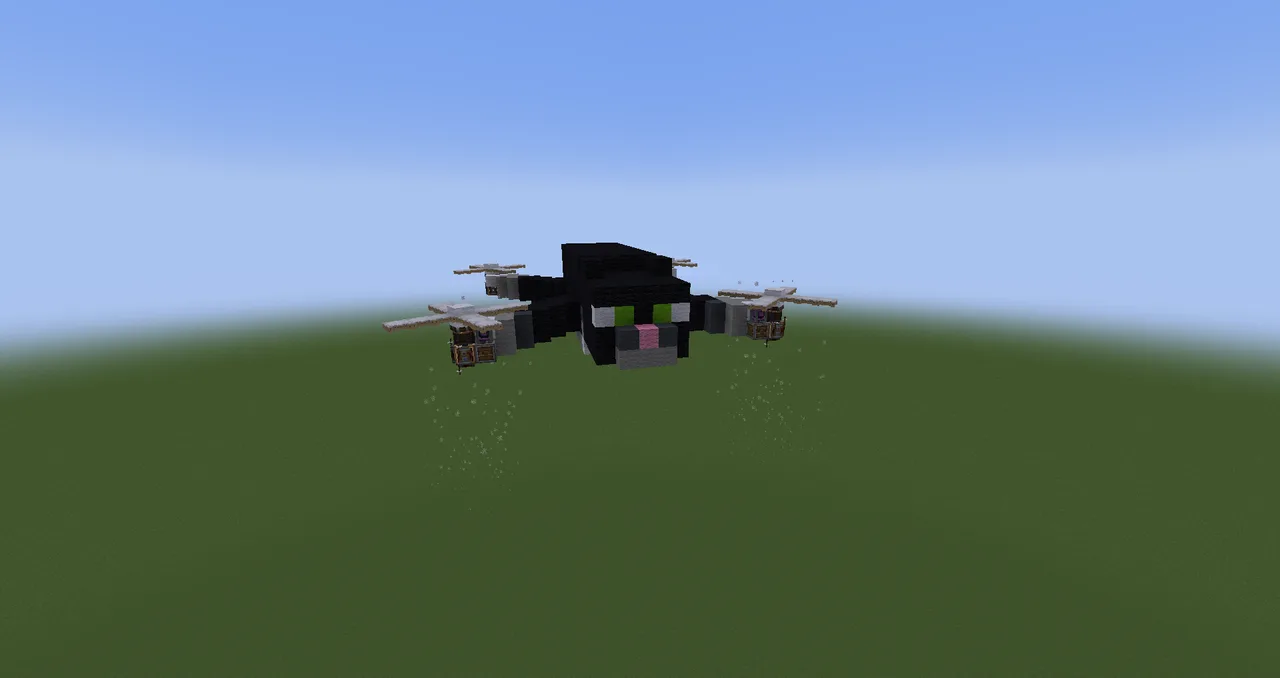 Orvillecopter - Flying Cat Drone608 blocks · Damir28v
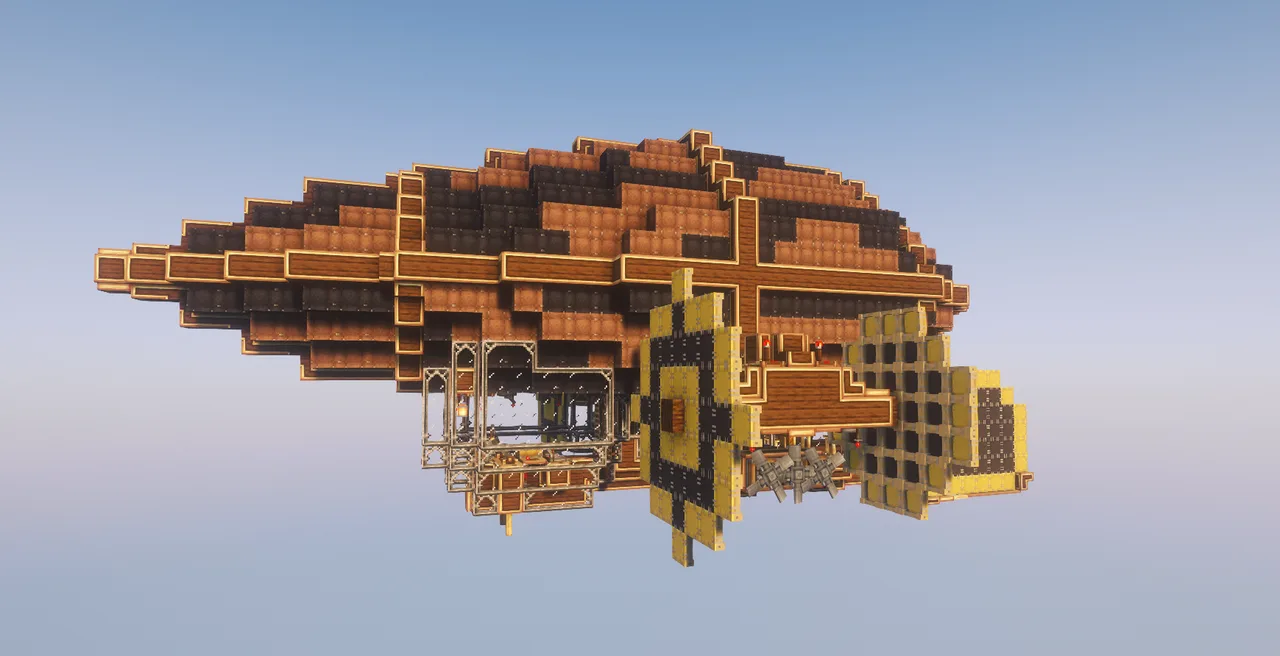 Flight-focused Brass Airship (Survival Friendly)2,145 blocks · Dumpling
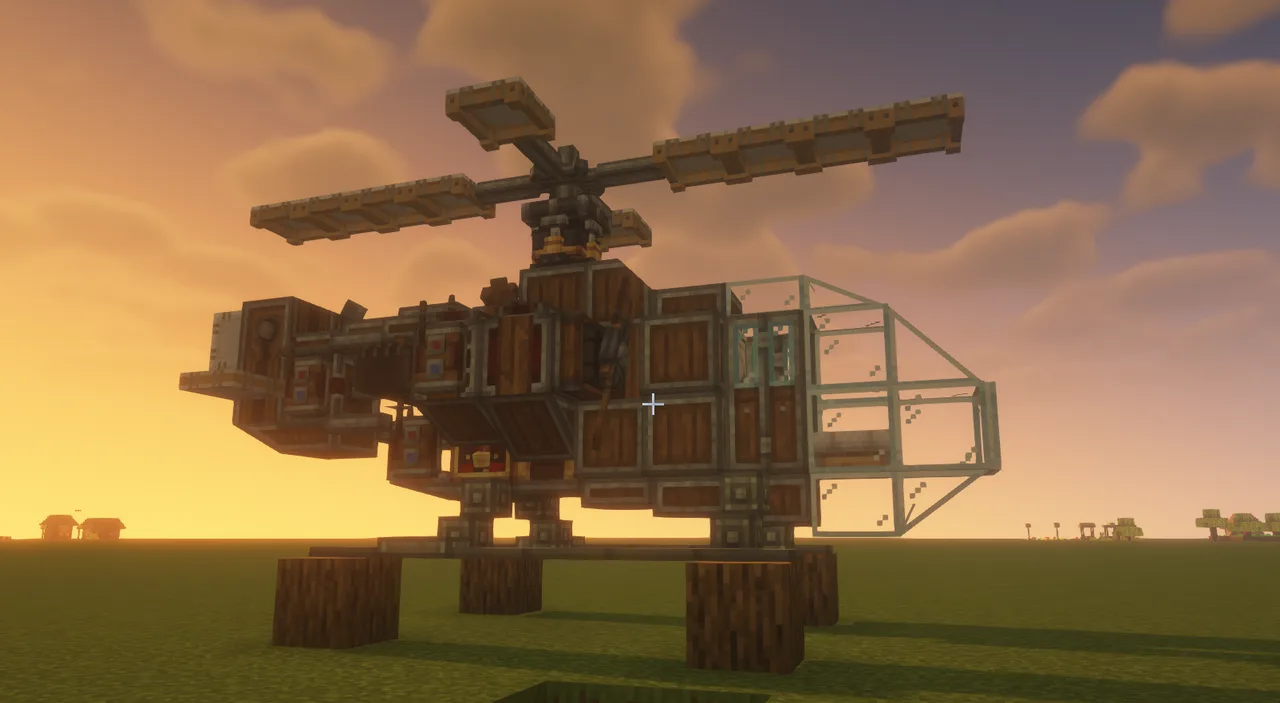 Small helicopter125 blocks · Isayno
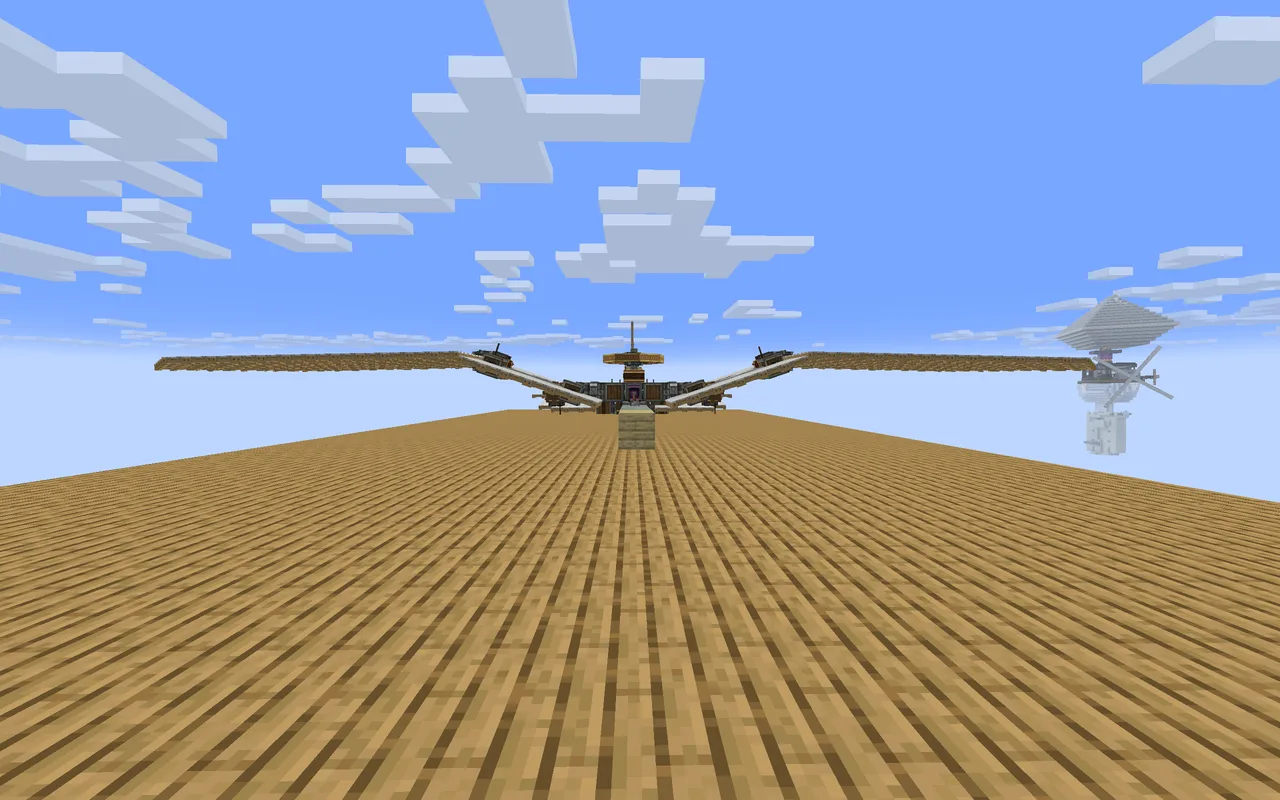 Ornithopter by Rkurbyko(working)7,733 blocks · Rkurbyko
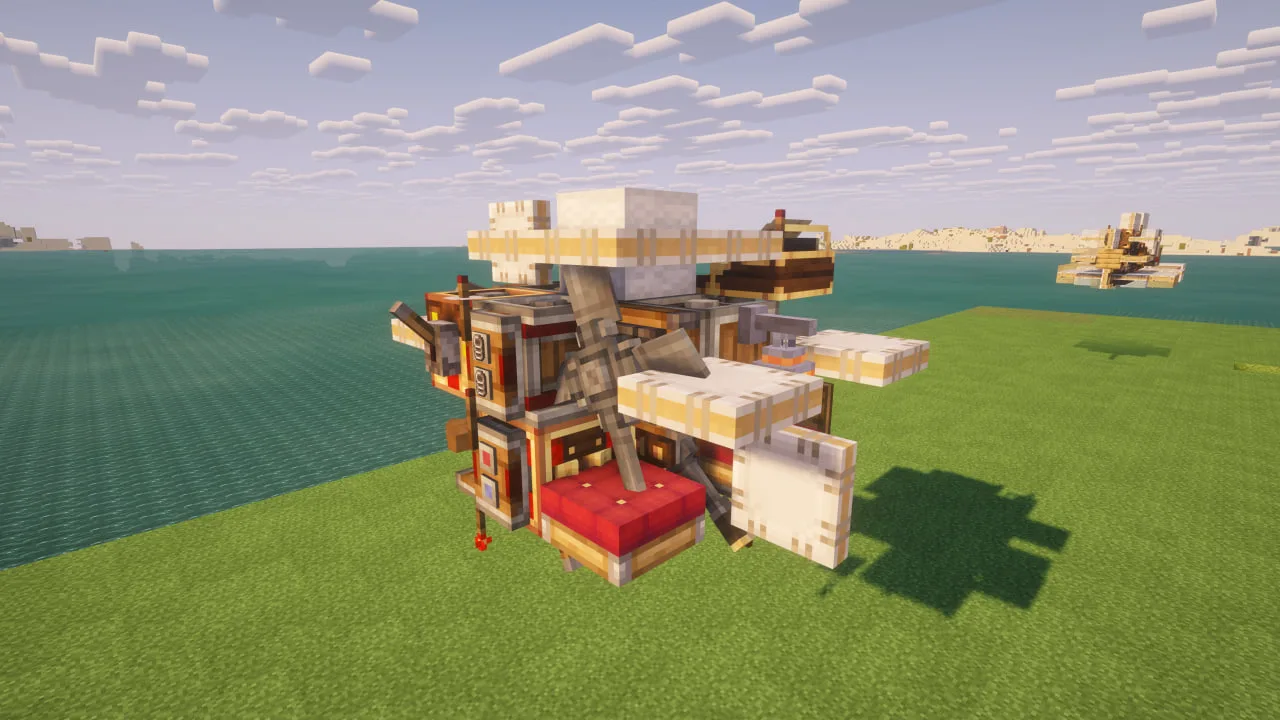 Smallest helicopter in Create Aeronautics possible!46 blocks · Xony1027
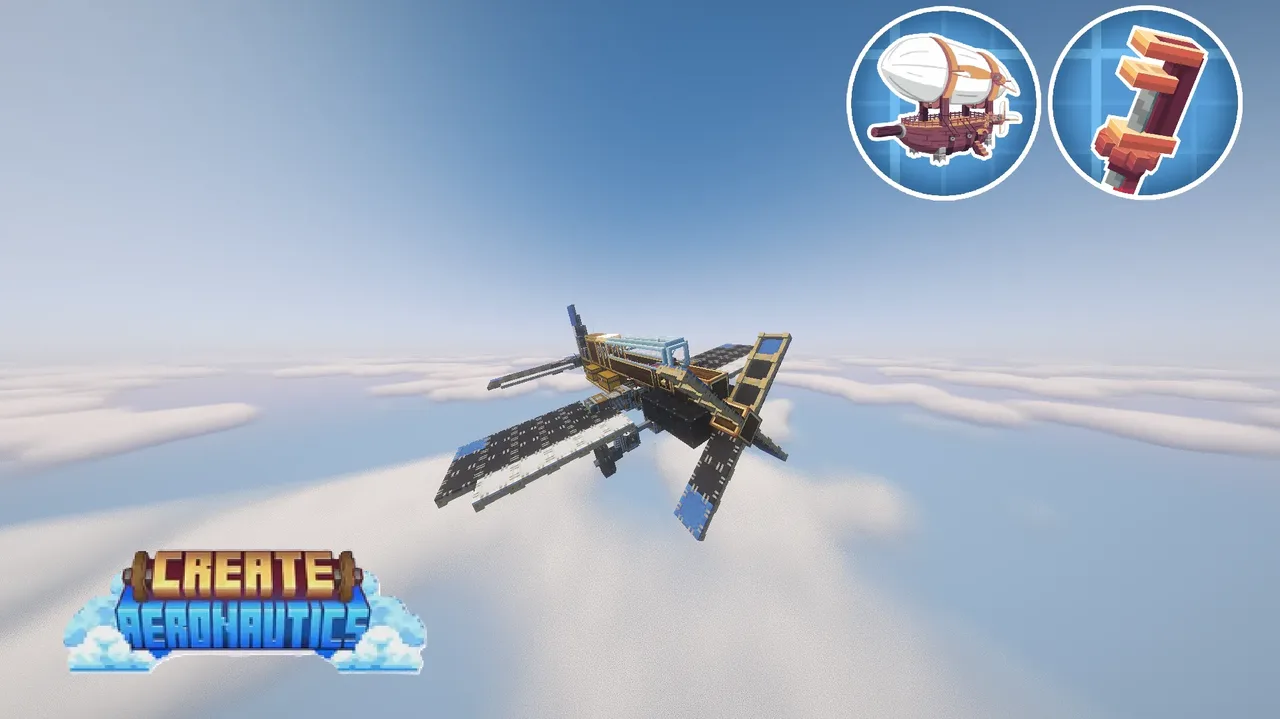 Small Airplane (Creative mode only)282 blocks · Kumajpn
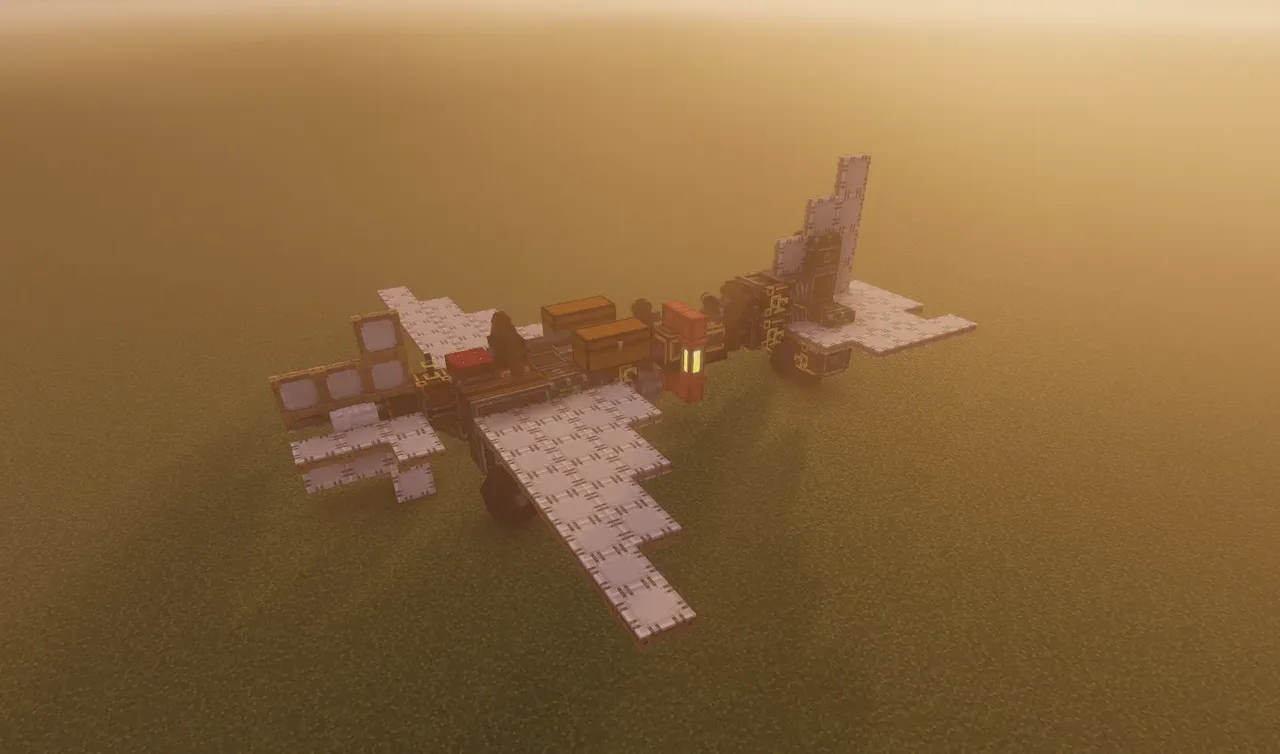 agile survival friendly plane176 blocks · Lukas092
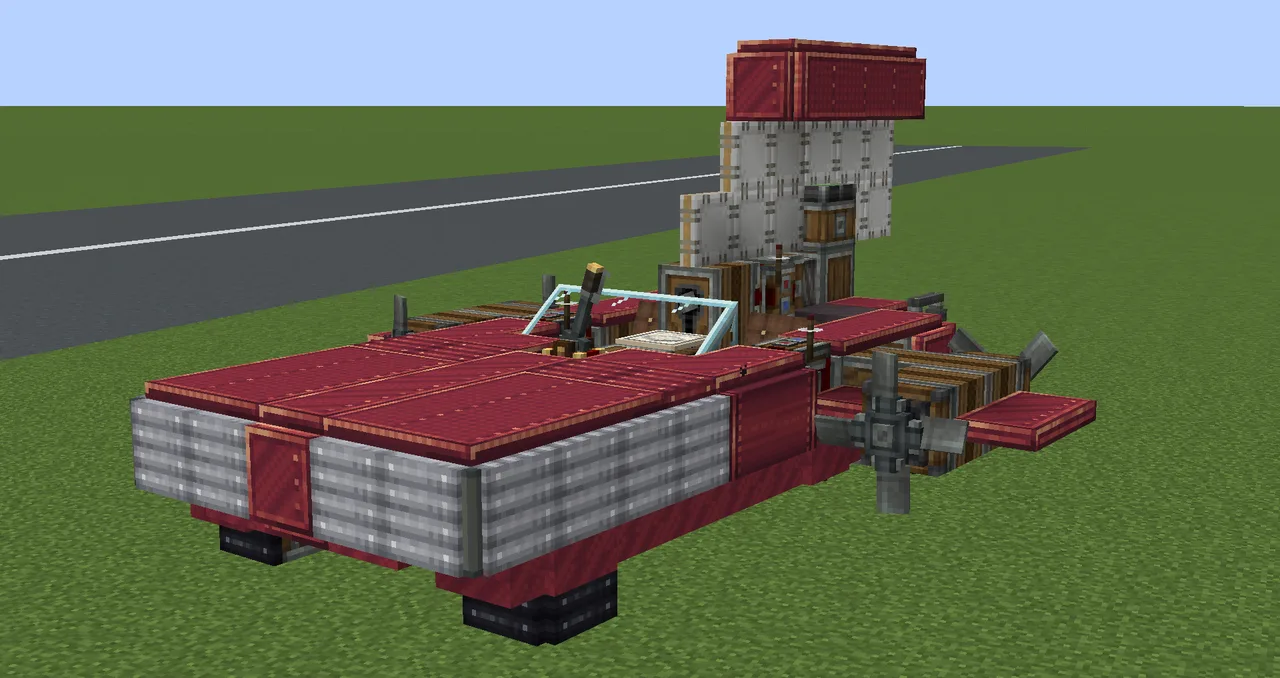 X-34 Land Speeder234 blocks · Deanandre
 copper flying ship (that can also act as a normal boat)722 blocks · Radturbotnt